MARITIME AUTOMATION · 2024-2025
Obstacle Avoidance for Maritime Vessels
A real-time detection and manoeuvring algorithm for a scale-model bulk cargo vessel.
Navigation with awareness.
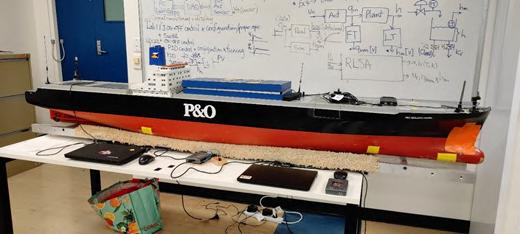
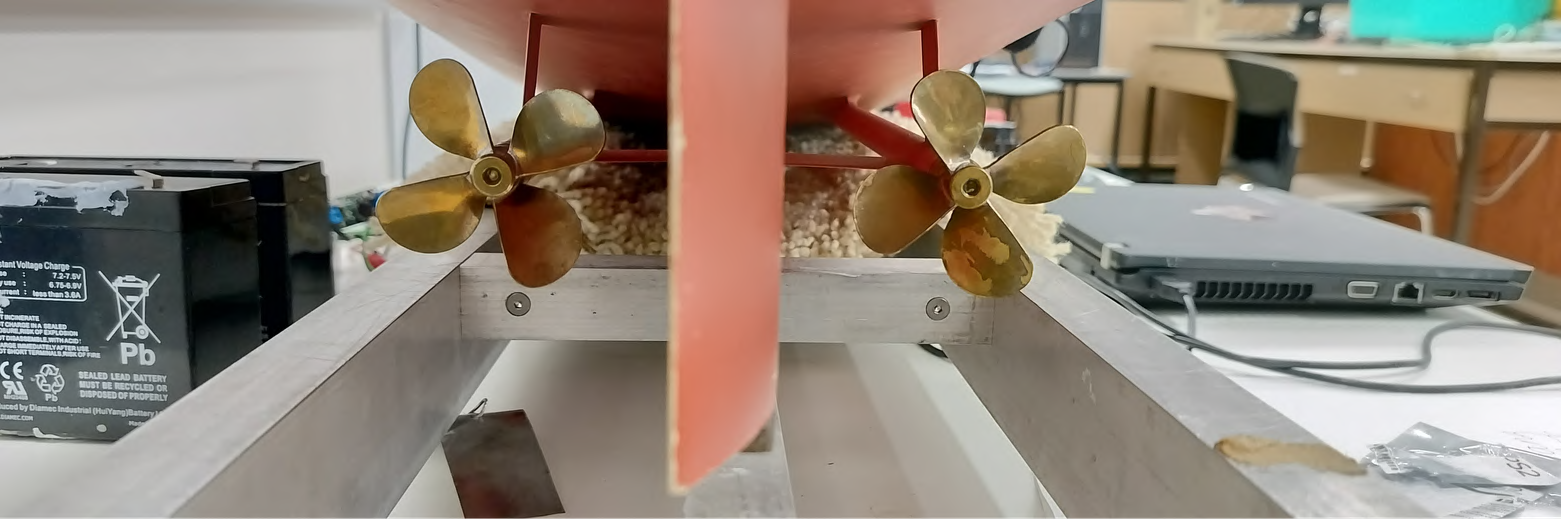
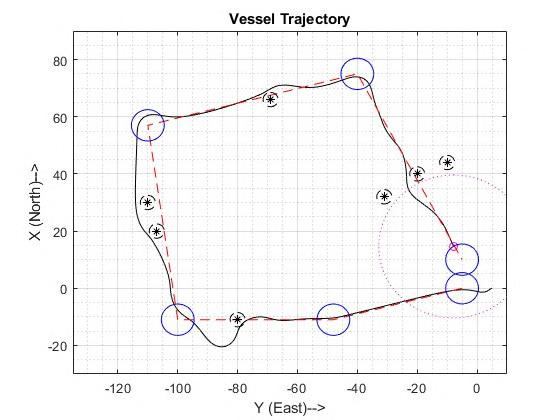
This project introduced me to maritime automation. I developed a real-time obstacle-avoidance algorithm for the scale model bulk cargo vessel Nedlloyd Hoorn. Ultrasonic sensors detected obstacles in the vessel’s path and the control logic manoeuvred the vessel to avoid collision while progressing through set checkpoints.
- Model dimensions
- LBP 3 m · B 28 cm · D 30 cm
- Method
- Velocity Obstacle Method
- Tools
- MATLAB and NI myRIO
- Scope
- Collision avoidance on a model vessel
Development focus
- Developed and tested real-time control logic in MATLAB.
- Integrated hardware and software using an NI myRIO board and sensor suite.
- Applied PID closed-loop development and tuning.
- Built troubleshooting, research and documentation skills.
- Worked with Guidance, Navigation and Control theory and COLREG collision-avoidance regulations.